Gripping Modules
Select gripping technology by part geometry, machine process and end-of-arm tooling requirement.
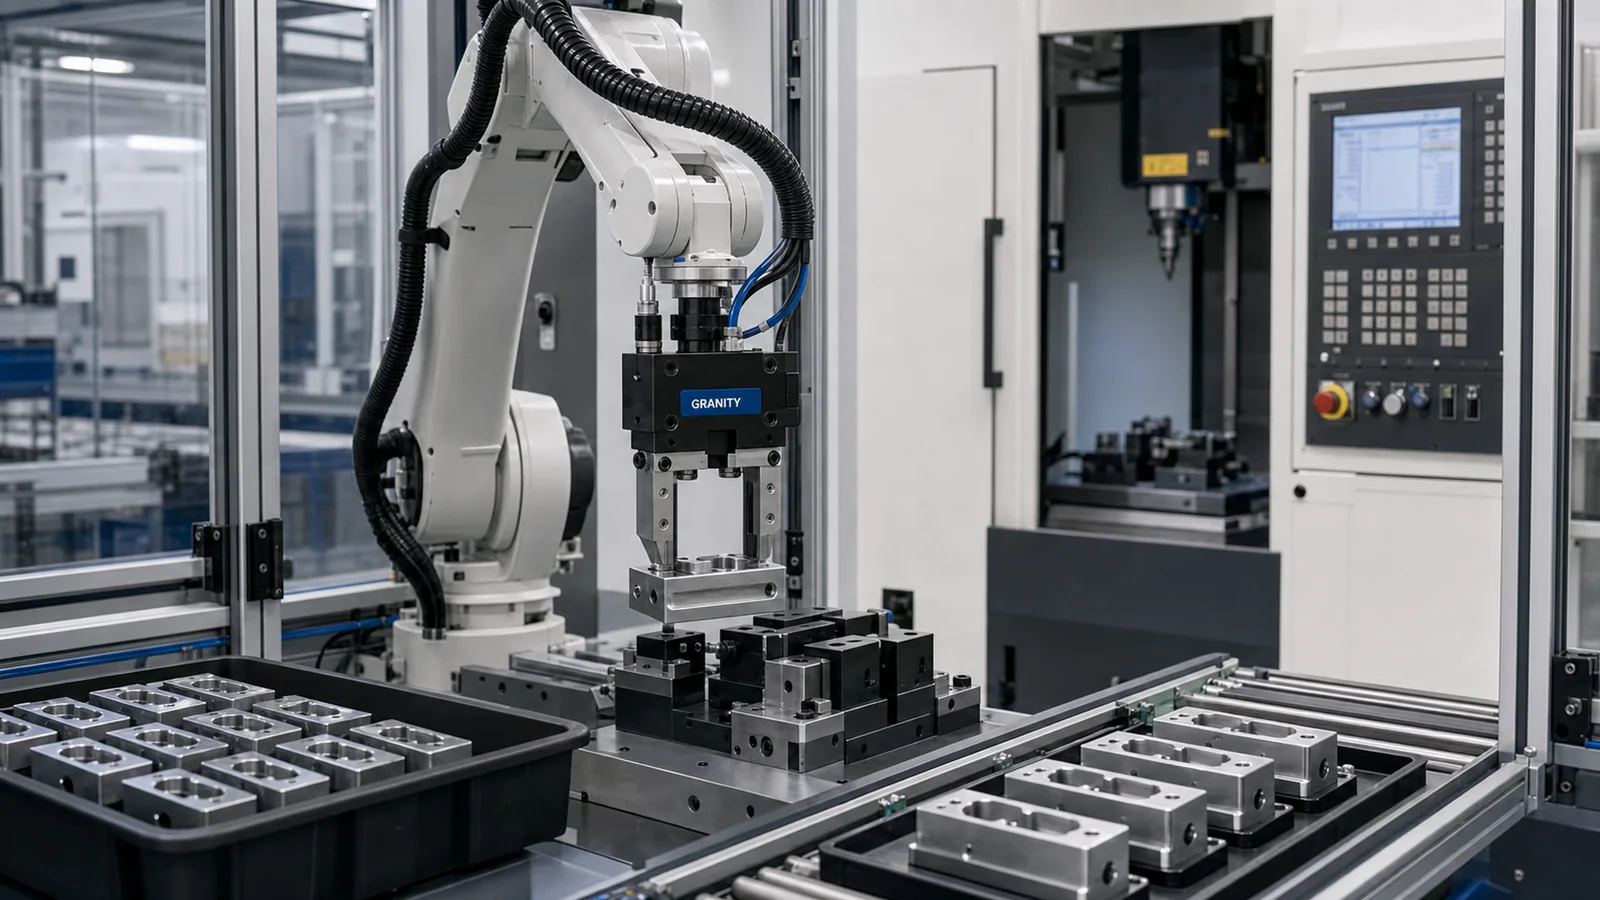
Product Categories
Parallel Grippers
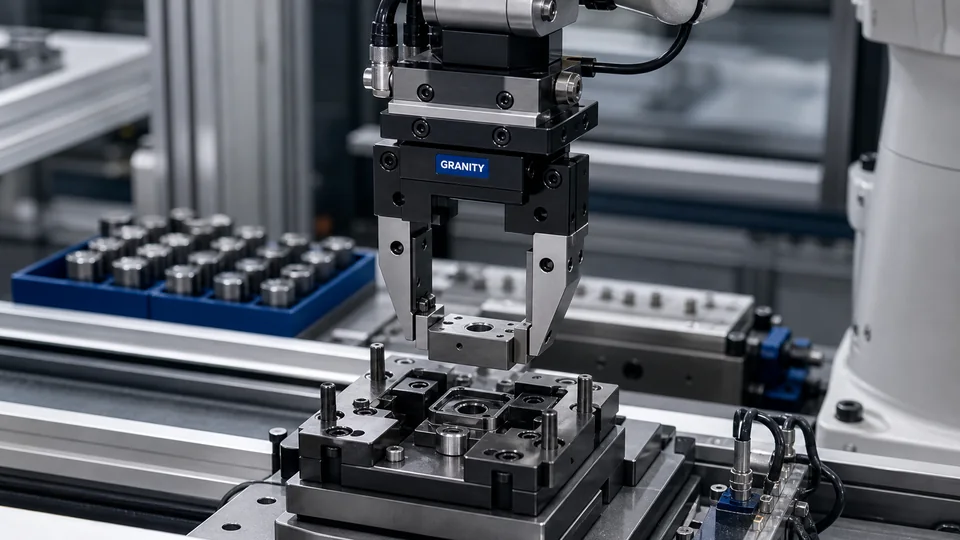
Two-finger linear gripping for machine tending, assembly transfer and general part handling.
Review Parallel Grippers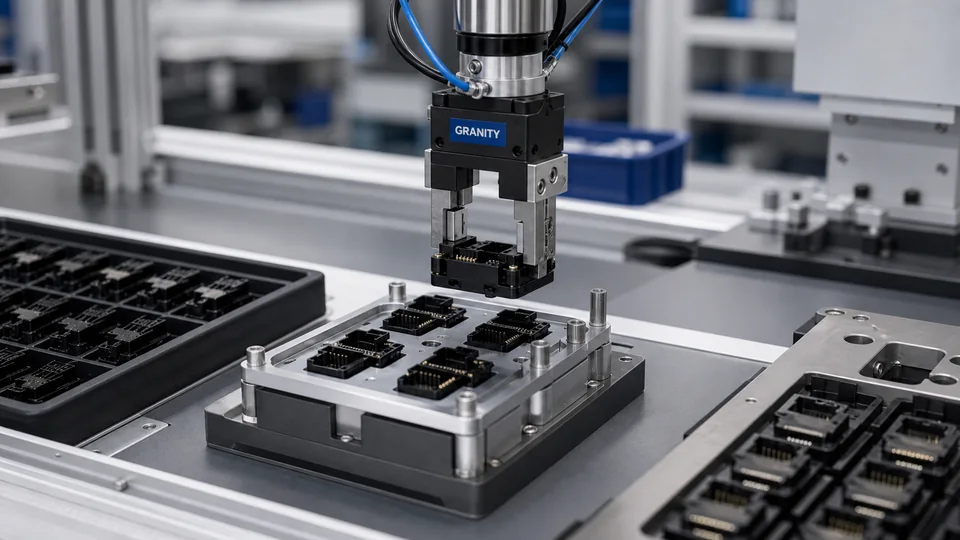
Angular Grippers
Pivoting jaw motion for compact access, shaped parts and fixture clearance constraints.
Review Angular Grippers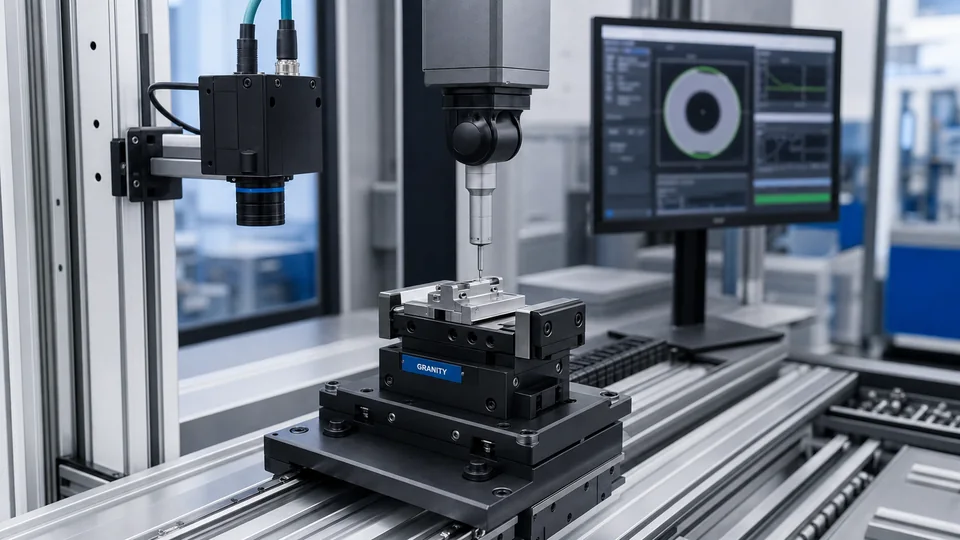
Centric / 3-Jaw Grippers
Centered gripping path for round, cylindrical and symmetrical workpieces.
Review Centric Grippers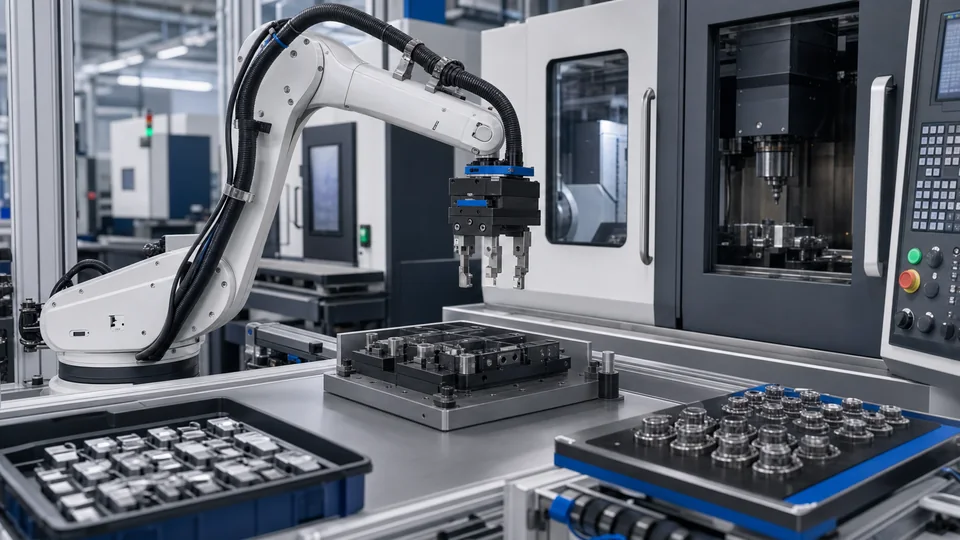
Pneumatic Grippers
Air-actuated gripping modules for high-cycle production and simple utility integration.
Review Pneumatic Grippers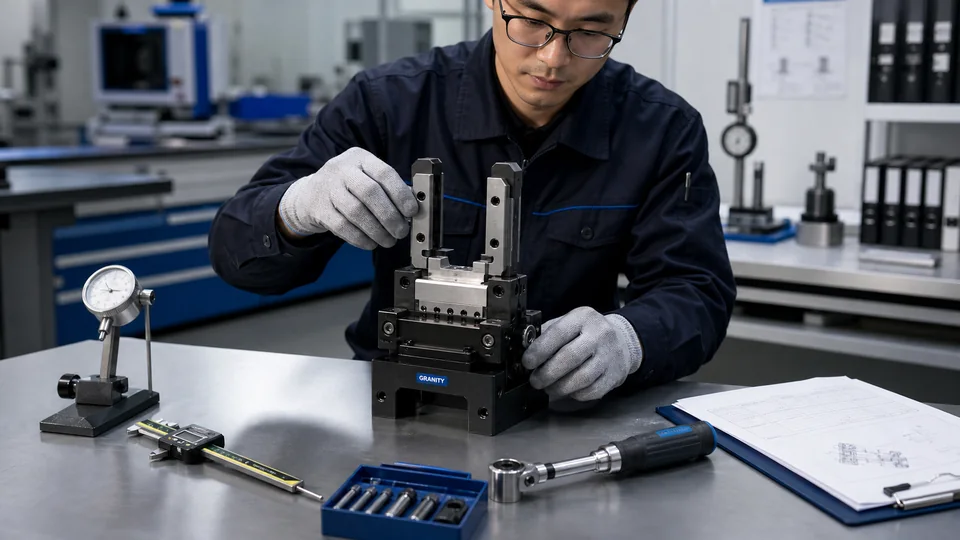
Rotary Modules
Rotary handling and positioning modules for orientation changes in automated sequences.
Review Rotary Modules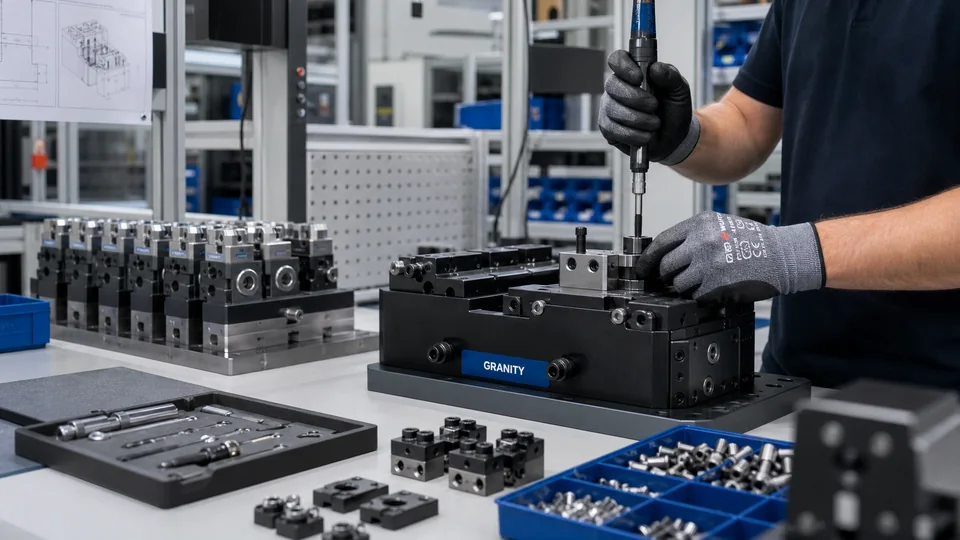
Quick Change Systems
Interfaces for faster end-effector replacement, maintenance and flexible cell planning.
Review Quick Change SystemsWhere gripping modules fit.
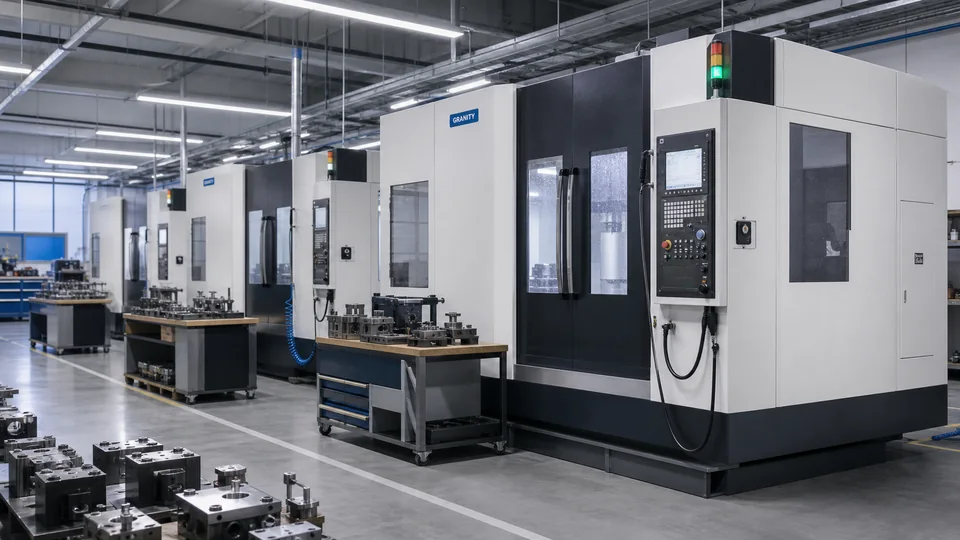
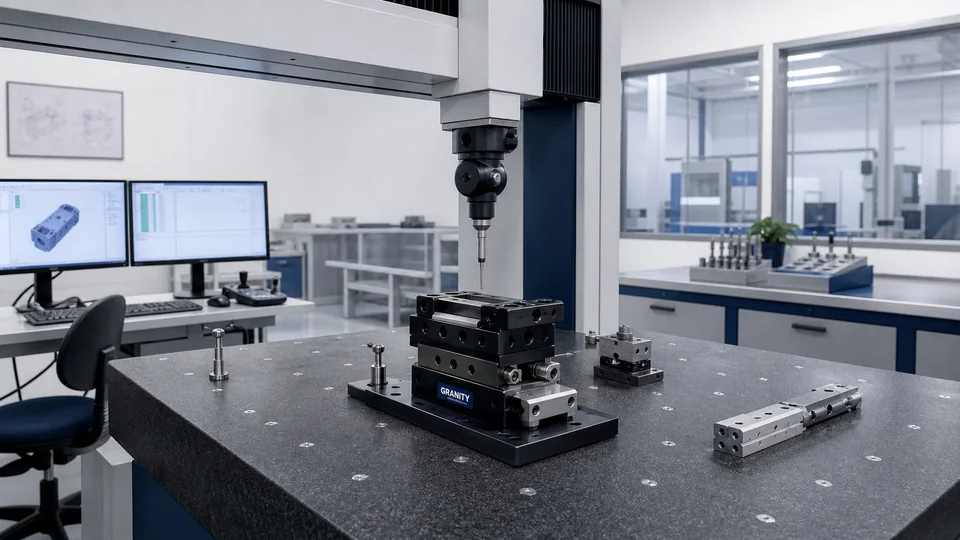
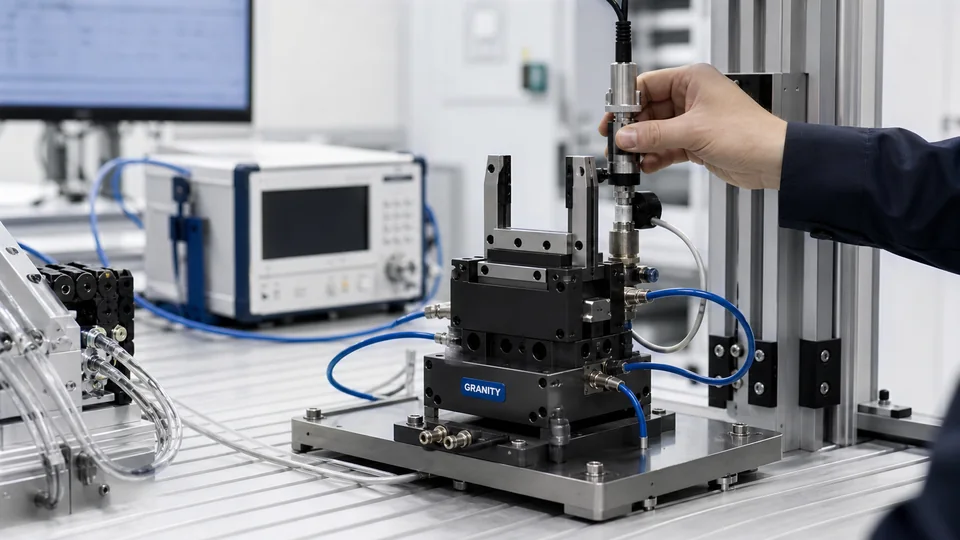
Use this family when the application needs a mechanical interface to pick, hold, center or transfer a workpiece during machine loading, assembly, packaging or inspection.
For project-specific selection, share the workpiece, target motion and machine or robot interface. GRANITY can then connect the right family to CAD, datasheet or quotation support.
Typical Applications
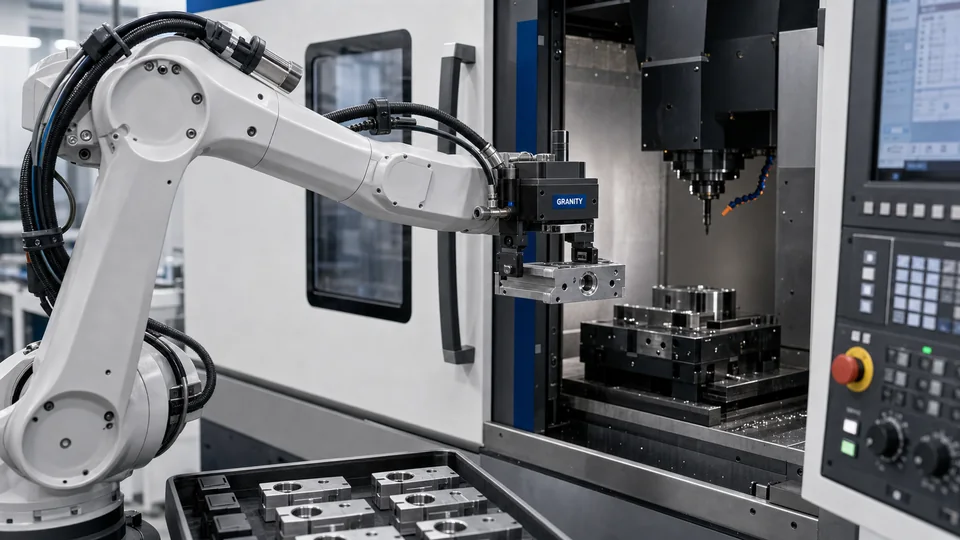
Prepare these details before CAD or RFQ.
Next step for gripping selection.
Share the workpiece, machine, target family or CAD requirement. GRANITY can help identify whether a parallel, angular, centric, pneumatic or quick-change path fits the application.